
HCCEPose
从一张 RGB 图像
估计已知物体的 6D 位姿6D pose estimation
from a single RGB image
HccePose(BF) 同时预测物体前、后表面的坐标,再通过 2D–3D 对应求出物体相对于相机的旋转和平移。HccePose(BF) predicts coordinates on the front and back surfaces of a known object. These 2D–3D correspondences give the rotation and translation of the object relative to the camera.
图像输入Image input
前后表面联合预测Front and back surfaces
超密集对应Ultra-dense correspondences
旋转与平移Rotation & translation
方法METHOD
一个像素,
两个表面点One pixel,
two surface points
同一条相机射线
与物体前、后表面相交。Where a camera ray meets
the object surface
沿这条射线,最近的表面交点对应前表面,最远的交点对应后表面。网络分别预测两个交点的层次化连续坐标编码。解码后,同一个图像像素就能对应物体坐标系中的两个三维点。The nearest intersection lies on the front surface and the farthest on the back surface. The network predicts a hierarchical continuous coordinate code for each. Decoding both gives two 3D points in the object coordinate frame for the same pixel.
查看方法详解Read about the method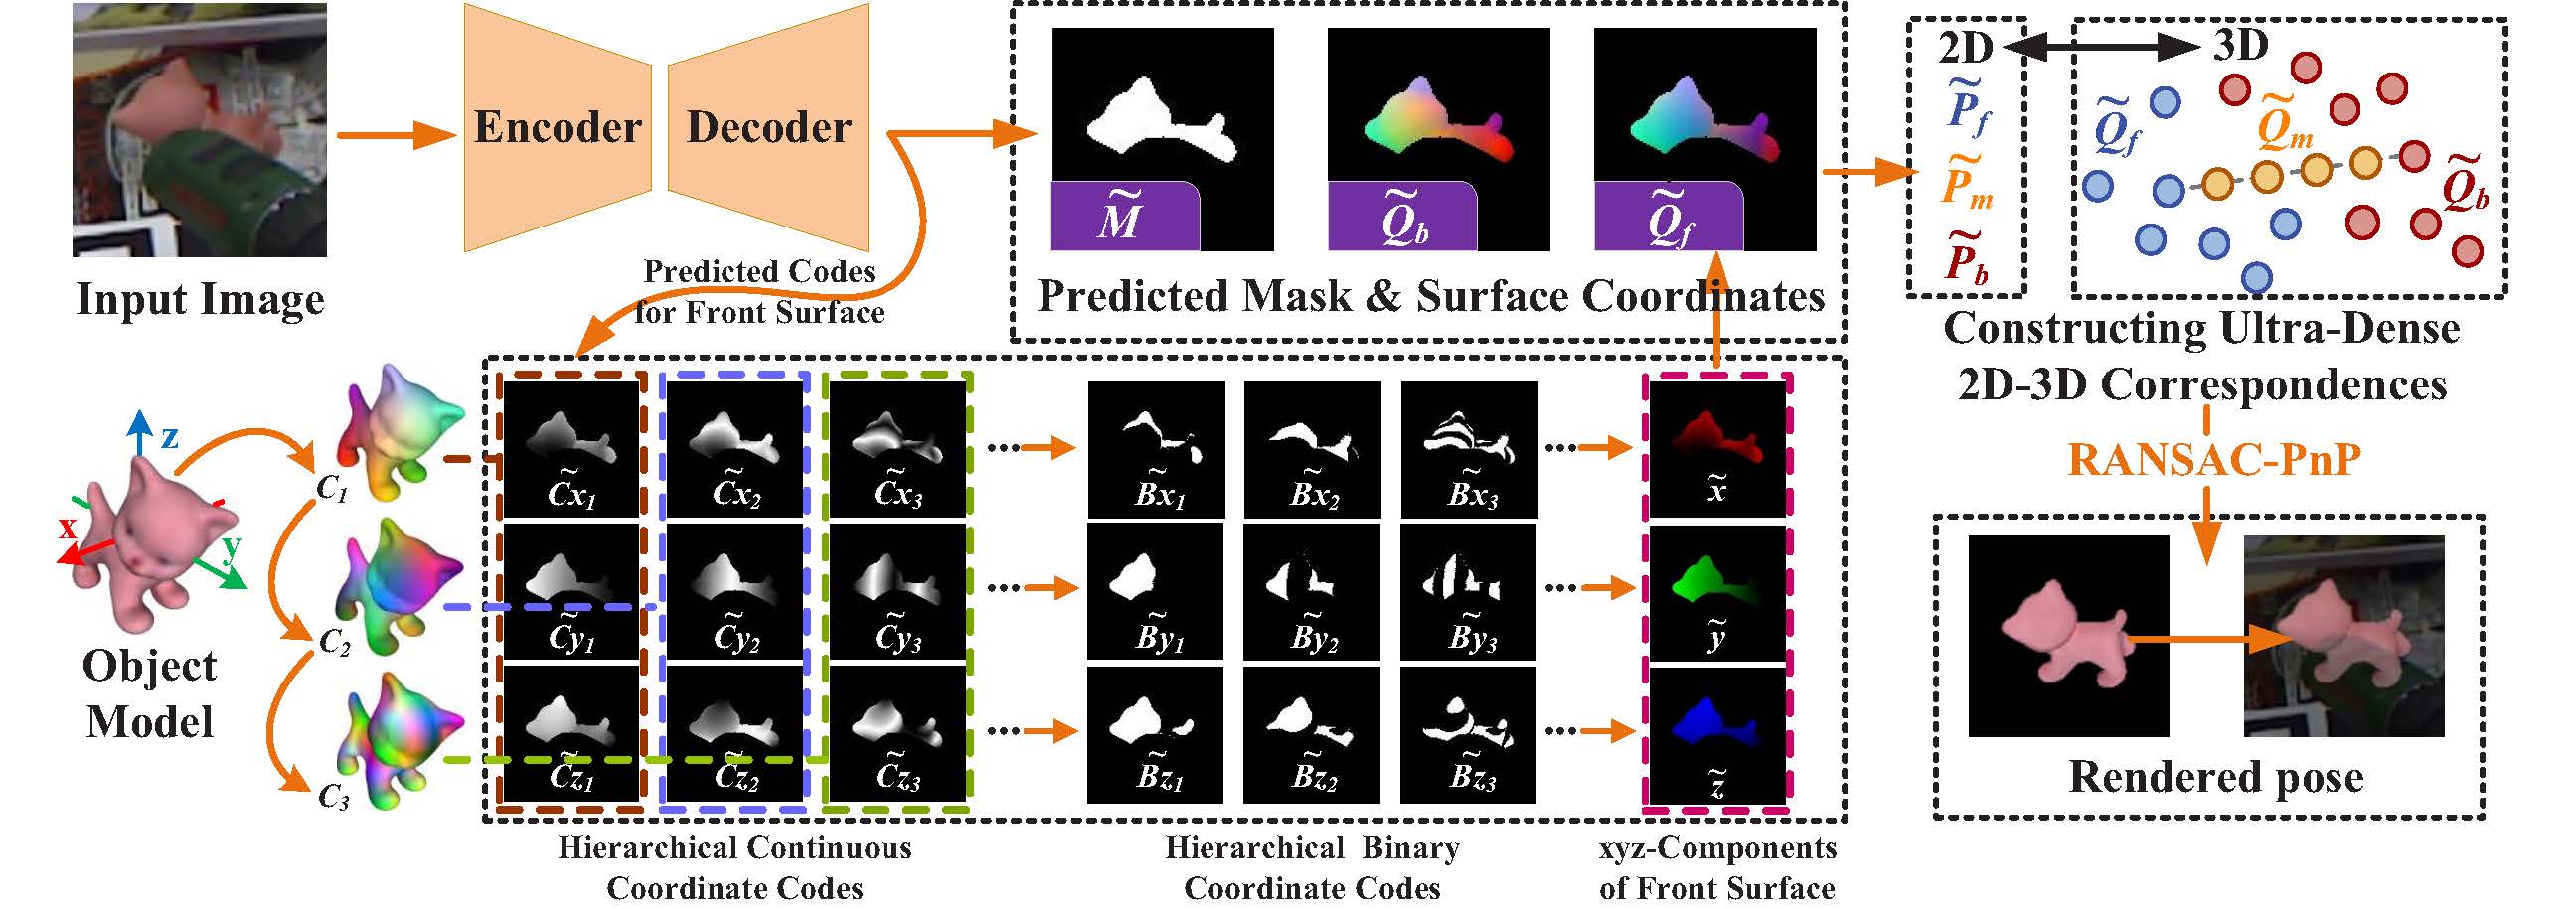
- 01
检测与表面预测Detect & predict surfaces
YOLO 检出物体后,HccePose 在裁剪区域内预测掩码和前、后表面的坐标编码。YOLO detects the object. HccePose predicts a mask and coordinate codes for both surfaces in the cropped image.
- 02
构建 2D–3D 对应Match pixels to 3D points
解码前、后表面坐标,将掩码内的像素与对应的三维点配对。Decode the surface coordinates and pair each pixel inside the mask with its 3D points.
- 03
求解 6D 位姿Estimate the 6D pose
结合相机内参,用 PnP 求解物体到相机的旋转和平移。Solve PnP with the camera intrinsics to recover object-to-camera rotation and translation.
检测器可以识别多个类别,位姿权重按物体加载。准备匹配的模型与相机内参,即可接入自己的图像。The detector can identify multiple categories; pose weights are loaded per object. Supply matching models and camera intrinsics to work with your images.
示例EXAMPLES
料箱中的
物体位姿Object poses
in a bin
公开图像、视频,
以及三角块 RGB-D 交互。Published images, video,
and triangular-part RGB-D interaction.
查看公开图像与视频示例,再通过公开 WAPR 接口接入配准深度与实例掩码。Explore published image and video examples, then connect registered depth and instance masks through the published WAPR API.
彩色图像 → 物体位姿RGB → 6D POSE
单张 RGB 图像中的
多个物体实例Multiple instances
in one RGB image
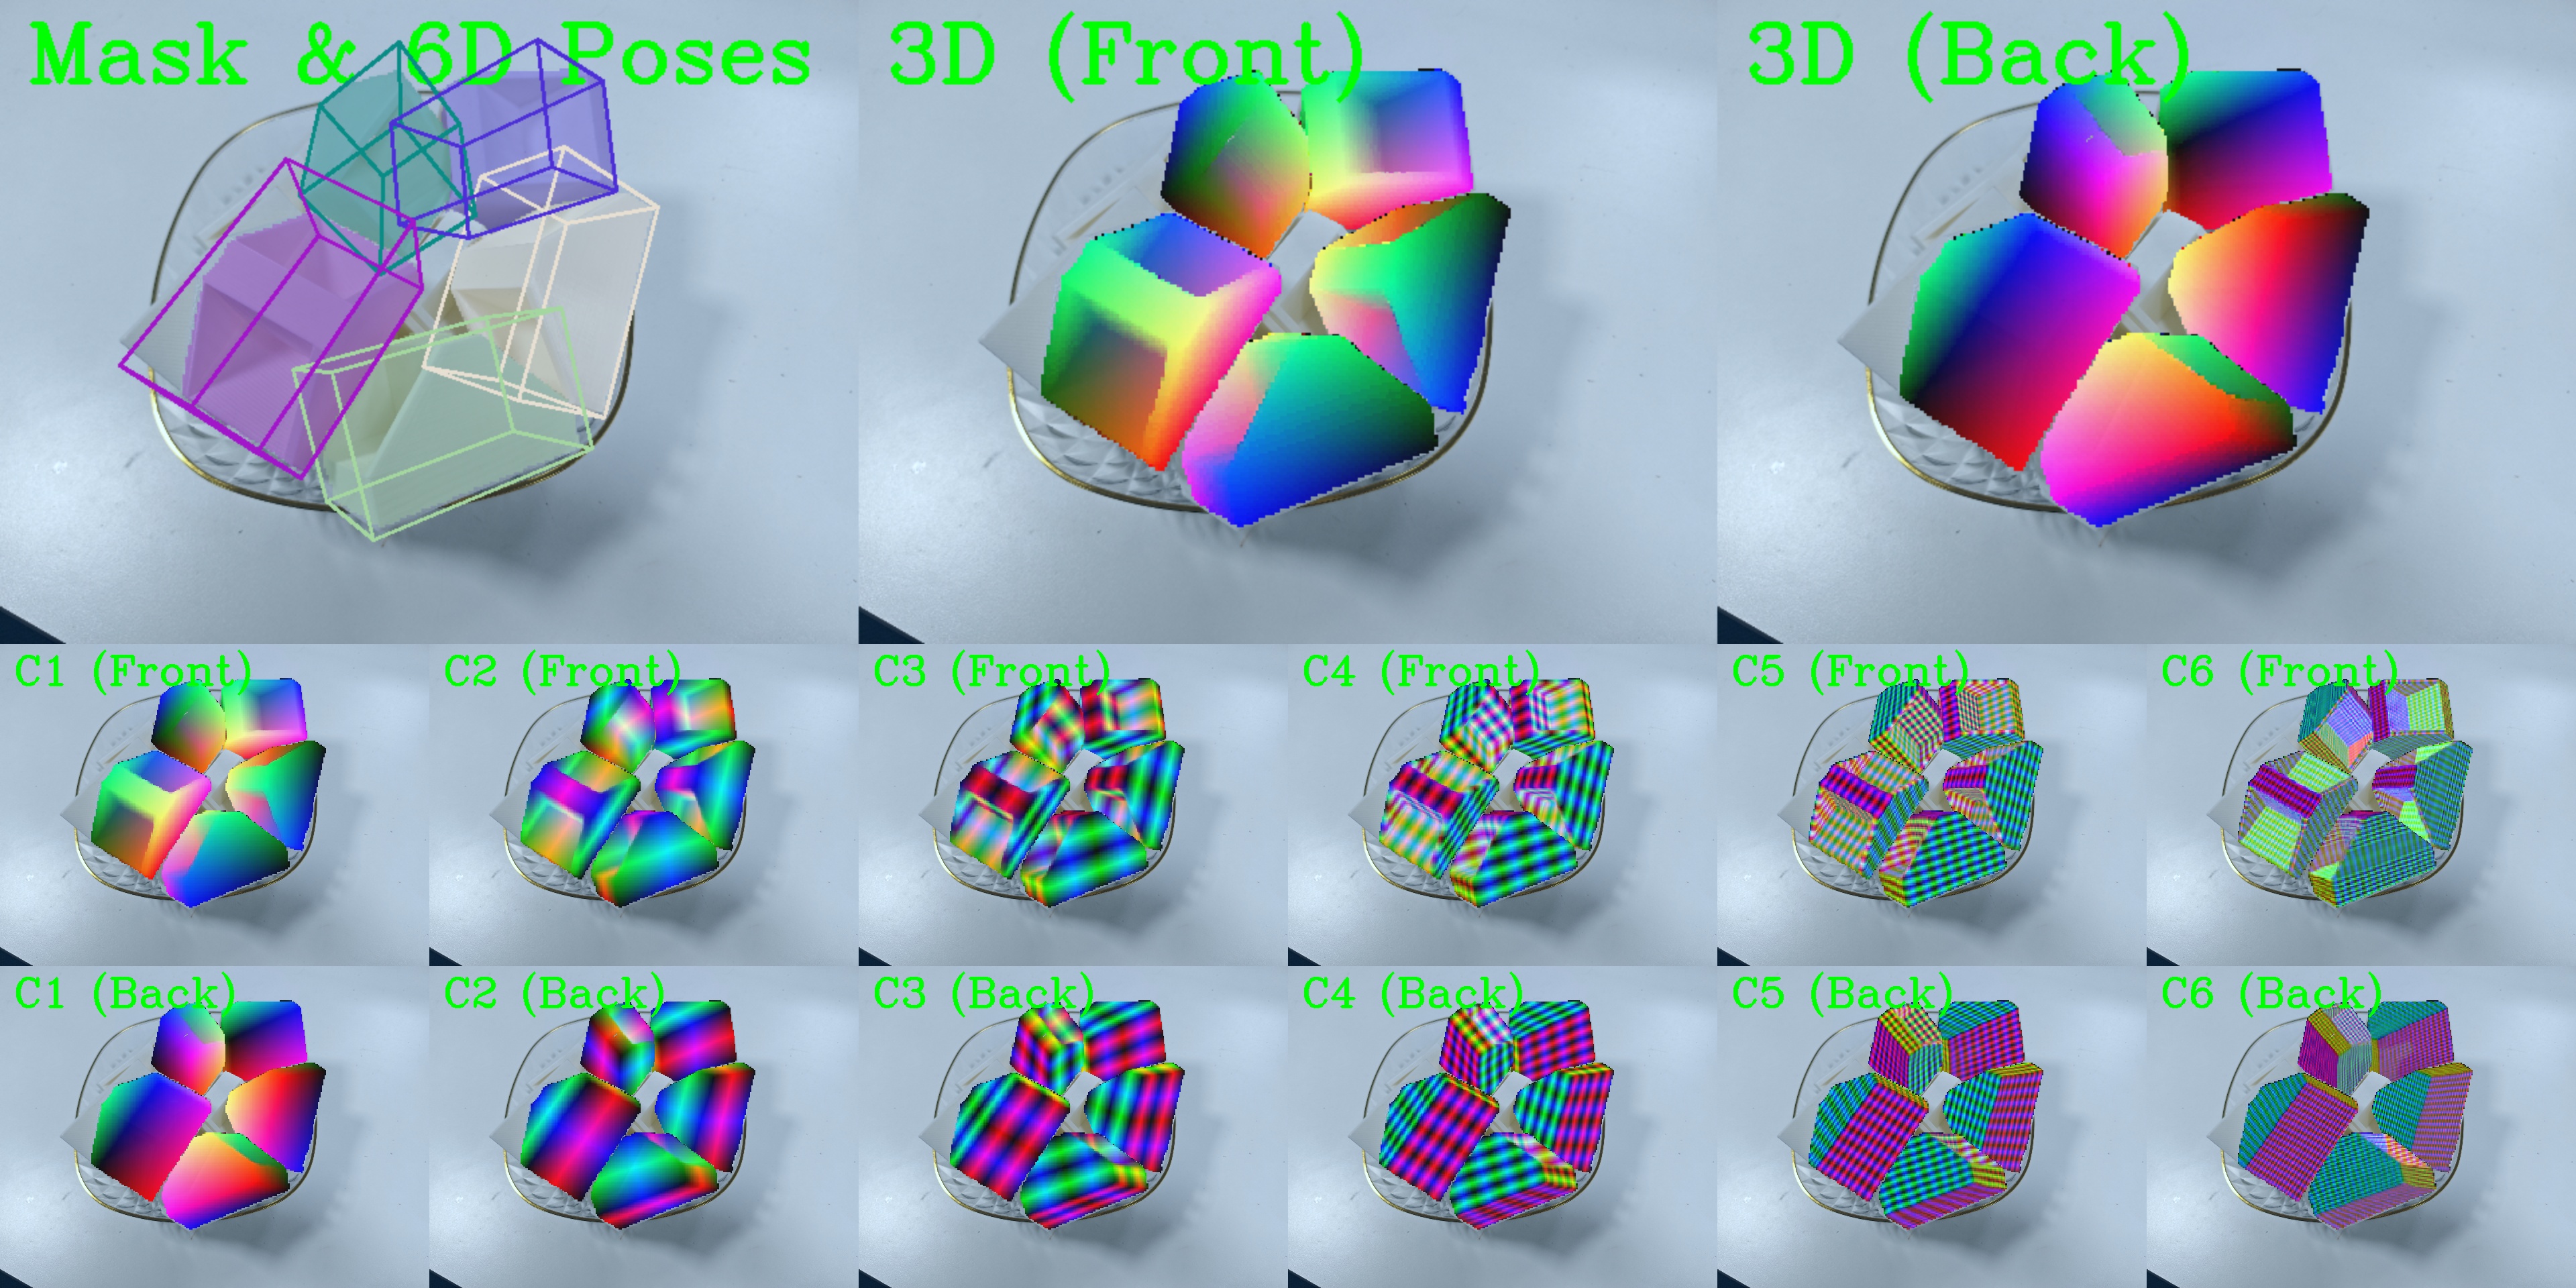
示例并排显示各个实例的预测掩码、前后表面坐标,以及按估计位姿投影到图像上的三维包围盒。For each instance, the panels show the predicted mask, front and back surface coordinates, and the 3D bounding box projected at the estimated pose.
输入:BGR 图像、相机内参、物体模型及对应权重Inputs: BGR image, camera intrinsics, object models and matching weights
运行 RGB 示例Run the RGB example使用文档DOCUMENTATION
从示例到
自己的物体From the demo
to your own objects
准备配套资源,运行公开接口,
把物体位姿接入你的应用。Prepare matching resources, run the published interfaces,
and bring object poses into your application.
运行第一个示例Run your first prediction
准备模型和权重,在自己的 RGB 图像上运行推理。Prepare matching models and weights, then run inference on your own RGB image.
接入自己的应用Use HccePose in your application
用 Tester 传入图像和内参,按约定的坐标系和单位读取位姿。Pass an image and camera intrinsics to Tester, then read the poses in the documented coordinate frame and units.
接入 WAPRConnect WAPR
传入实例掩码、配准深度与模型,读取米制位姿和评分。Supply instance masks, registered depth and models to receive meter poses and scores.