
BOP 评测
本页使用公开上游源码中的准备、训练或评测脚本。请先按安装说明获取该版本,并在上游源码根目录执行本页命令;当前项目中的 examples/inference/ 用于应用推理。
评测脚本为 BOP 的七个核心数据集生成分割和位姿预测。随仓库提供的配置使用 LM-O,物体 ID 为 [1, 5, 6, 8, 9, 10, 11, 12],骨干网络设置为 efficientnet_key=1。检测框来自 BOP 2023 提供的 GDRNPP 检测结果。如果换用其他数据集,请同时替换数据集路径、检测 JSON 和模型权重,并检查骨干网络配置。
python s4_p2_test_bf_pbr_bop_challenge.py
LM-O 的两个输出文件位于数据集目录下。CSV 中的运行时间填为 -1,表示未记录耗时。要得到基准分数,还需用官方评测工具为这些预测打分或提交到 BOP。
预训练权重
| 数据集 | 权重 |
|---|---|
| LM-O | Hugging Face - LM-O |
| YCB-V | Hugging Face - YCB-V |
| T-LESS | Hugging Face - T-LESS |
| TUD-L | Hugging Face - TUD-L |
| HB | Hugging Face - HB |
| ITODD | Hugging Face - ITODD |
| IC-BIN | Hugging Face - IC-BIN |
部分物体的最佳检查点标为第 0 轮。我们先训练只预测前表面的 HccePose,再从已有权重开始联合训练前后表面。第 0 轮表示在这次训练的检查点中,起始权重就取得了最高分。
LM-O 提交结果
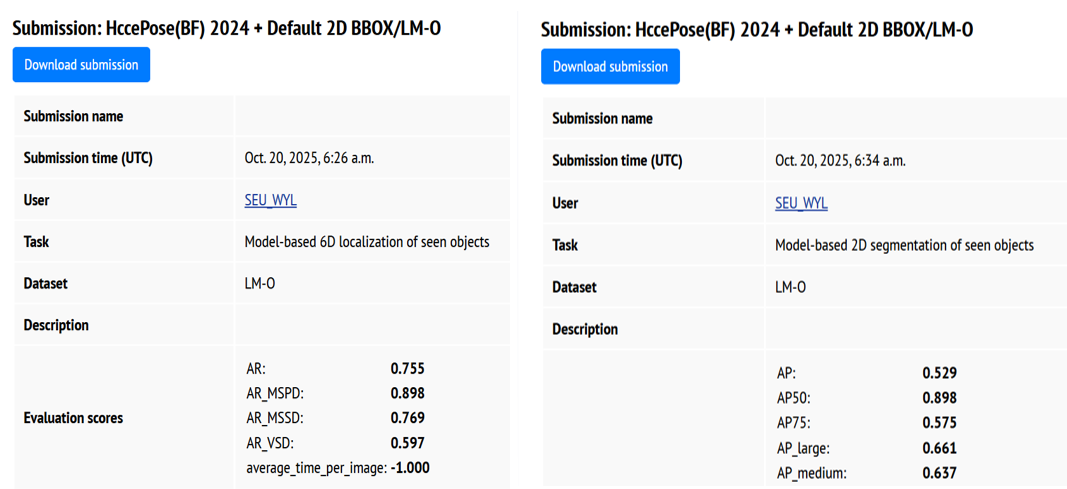
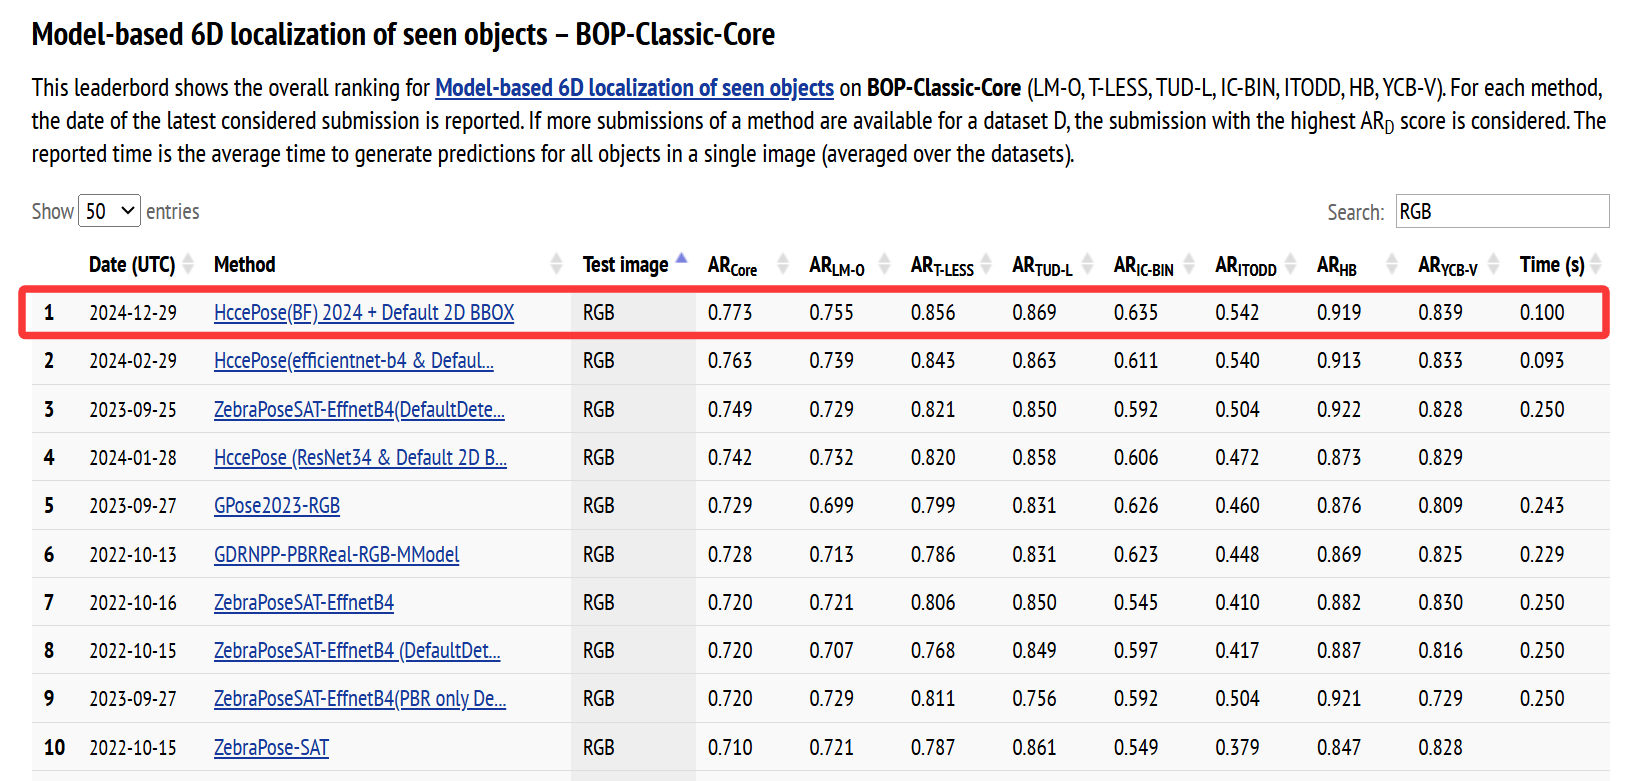
我们在 2025 年 10 月 20 日提交了以下两个文件。6D 定位分数与 2024 年的提交一致。修复分割实现中的问题后,2D 分割分数提高了 0.002。
- 2D 分割结果:seg2d_lmo.json
- 6D 位姿结果:det6d_lmo.csv
历史榜单截图
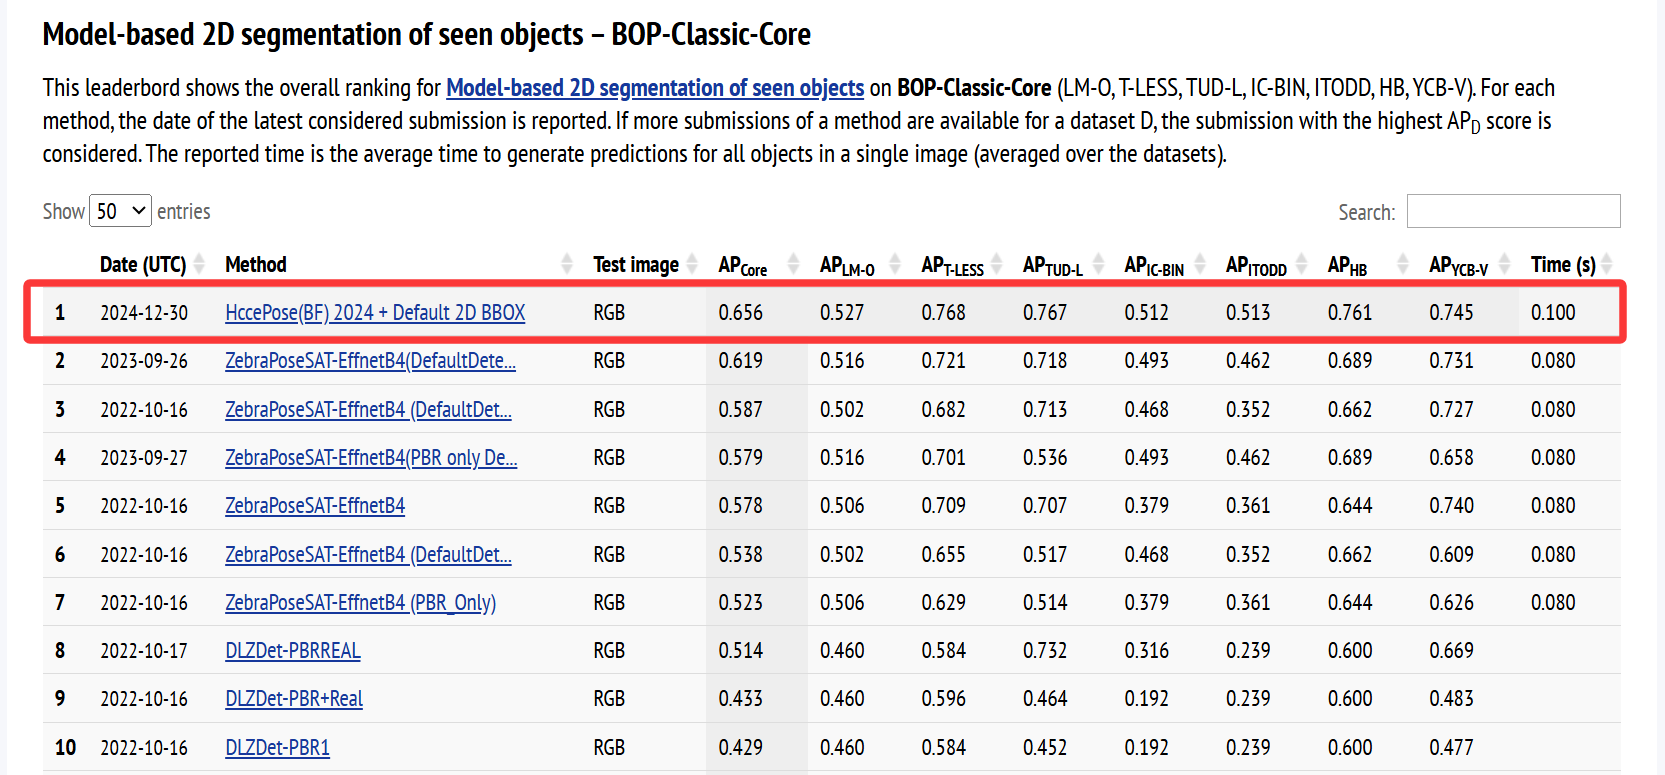
BOP evaluation
This page uses preparation, training or evaluation scripts from the public upstream source. Obtain that revision as described in Installation, and run these commands from its root. The current project’s examples/inference/ provides application inference.
The evaluation script generates segmentation and pose predictions for the seven core BOP datasets. The supplied configuration uses LM-O, object IDs [1, 5, 6, 8, 9, 10, 11, 12] and efficientnet_key=1. It reads the GDRNPP detections supplied for BOP 2023. To run on another dataset, update the dataset path, detection JSON and weights, and check the backbone setting.
python s4_p2_test_bf_pbr_bop_challenge.py
For LM-O, the script writes two prediction files to the dataset directory. It puts -1 in the CSV runtime field to indicate that runtime was not measured. To obtain benchmark scores, evaluate the predictions with the official tools or submit them to BOP.
Pretrained weights
| Dataset | Weights |
|---|---|
| LM-O | Hugging Face - LM-O |
| YCB-V | Hugging Face - YCB-V |
| T-LESS | Hugging Face - T-LESS |
| TUD-L | Hugging Face - TUD-L |
| HB | Hugging Face - HB |
| ITODD | Hugging Face - ITODD |
| IC-BIN | Hugging Face - IC-BIN |
Some objects have a best checkpoint labeled iteration 0. We train a front-surface HccePose model first and use its weights to initialize joint front and back training. Iteration 0 means those starting weights scored highest among the checkpoints evaluated in that run.
LM-O submission results
We submitted the following two files on October 20, 2025. The 6D localization score matched our 2024 submission. Fixes to the segmentation implementation improved the 2D segmentation score by 0.002.
- 2D segmentation results: seg2d_lmo.json
- 6D pose results: det6d_lmo.csv
Historical leaderboard screenshots